3D Computer Vision6D Pose EstimationVision-Language-ActionRobot Manipulation
Bio
I am a Ph.D. student at the Technical University of Munich,
sponsored by Siemens AG and supervised by Prof. Slobodan Ilic. My doctoral
research focuses on vision-language-action (VLA) models for robot manipulation.
Previously, I completed my M.Sc. in Robotics, Cognition, and Intelligence at the
Technical University of Munich. My research focuses on 3D computer vision,
with a specific interest in 6D pose estimation, object detection, and 3D scene understanding.
Before my time at TUM, I earned my B.Eng. in Mechatronics from Tongji University.
News
Started my Ph.D. at the Technical University of Munich.
SOS! and LEGAU were accepted to BMVC 2026.
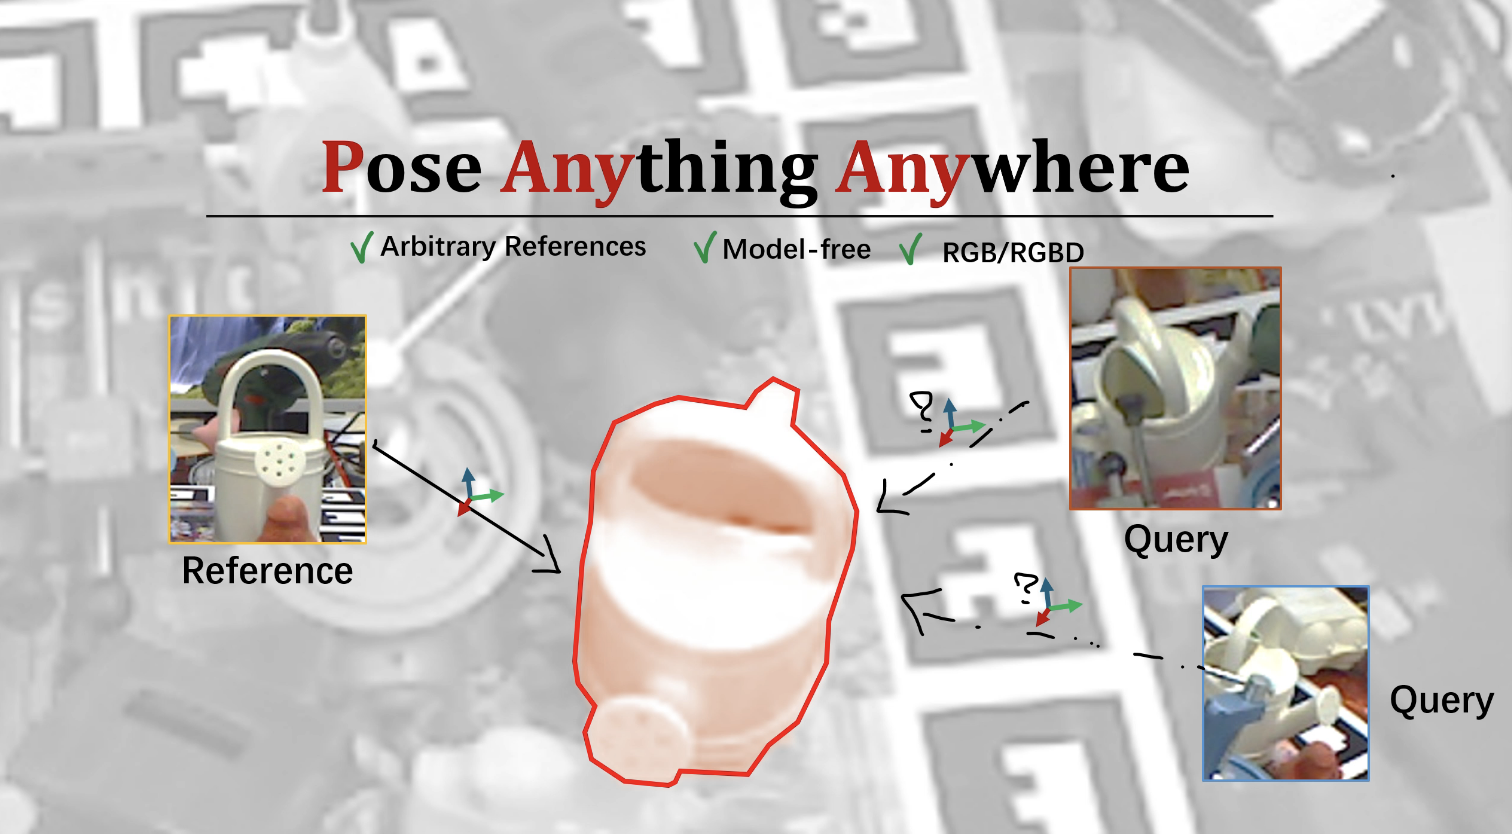
PANY and XYZ-IBD were accepted to ECCV 2026.
Defended my master's thesis and graduated with distinction from TUM.
Junwen Huang, Jiaqi Hu, Peter KT Yu, Slobodan Ilic, Martin Sundermeyer, Benjamin Busam
European Conference on Computer Vision (ECCV), 2026.
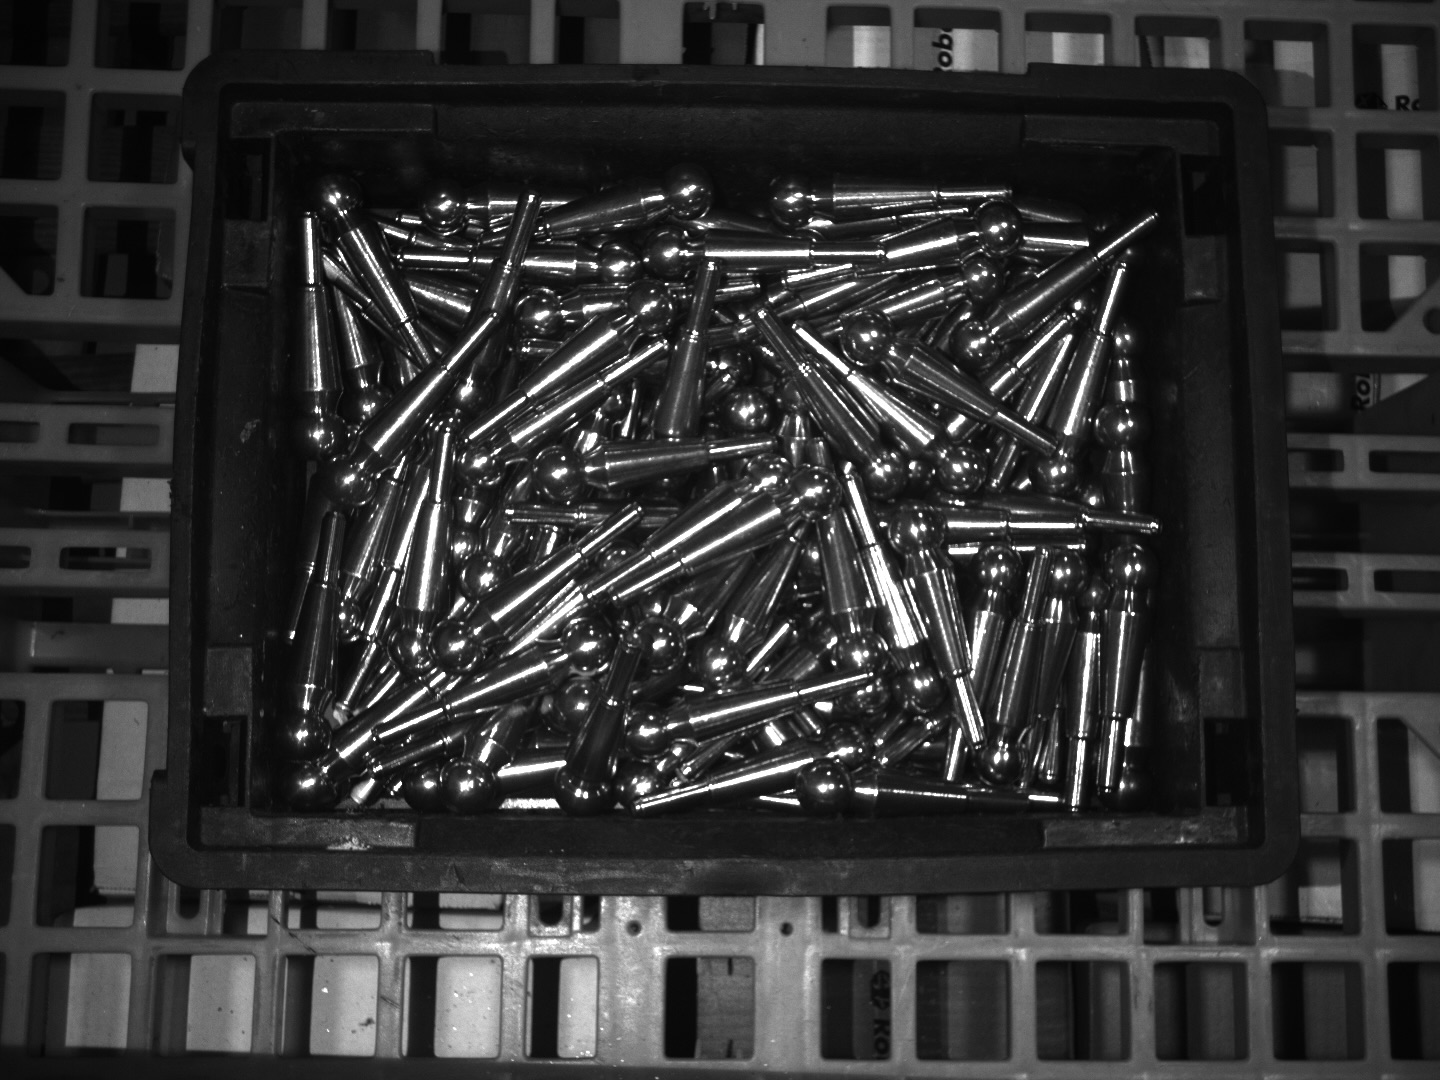
XYZ-IBD is a benchmark for object detection and 6D pose estimation in
industrial bin-picking scenes with metallic, specular, and highly occluded objects.
Jiaqi Hu, Hongli Xu, Junwen Huang, Peter KT Yu, Slobodan Ilic, Benjamin Busam
ICCV 2025 Workshop on Recovering 6D Object Pose, 2025.
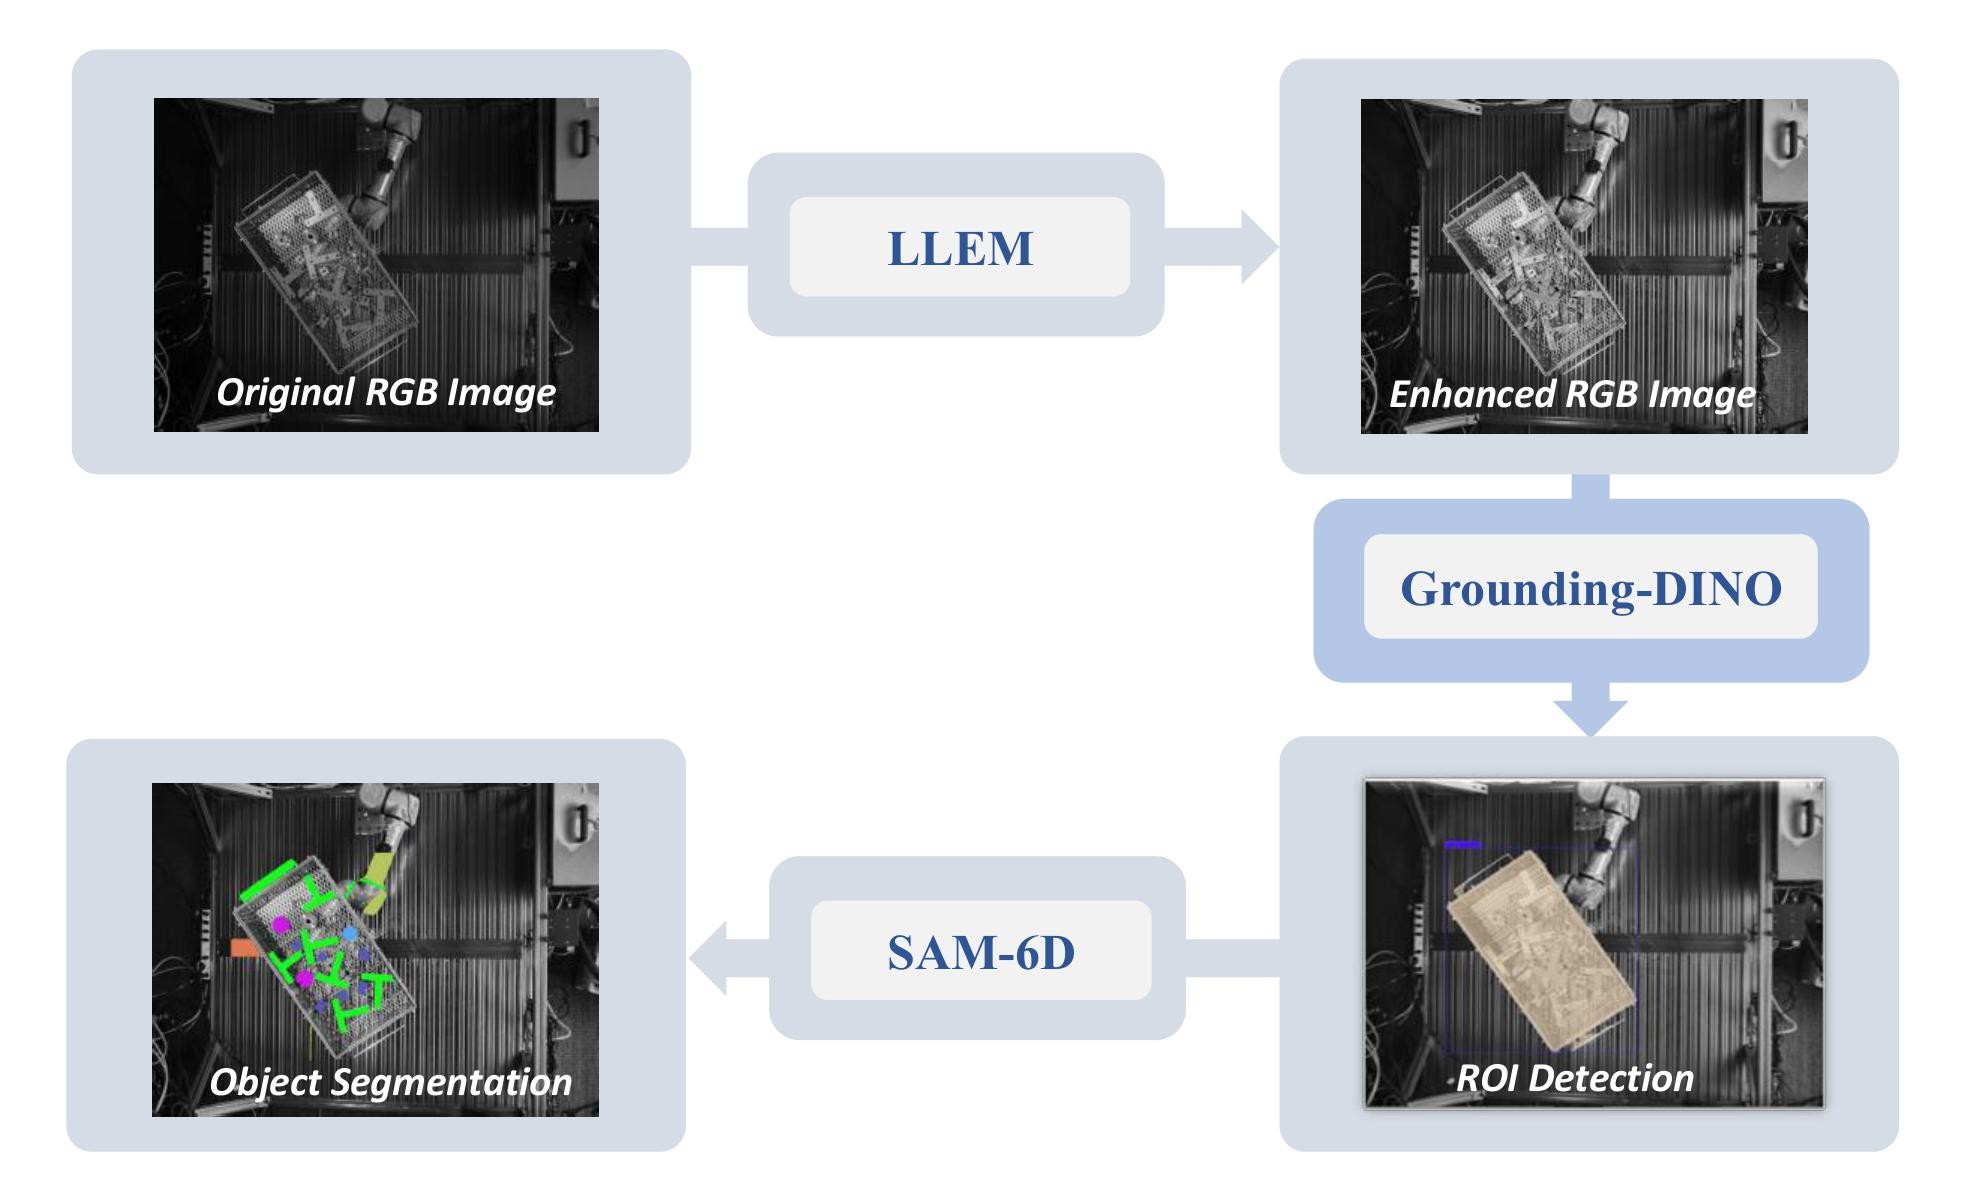
BioDet improves industrial object detection for downstream 6D pose estimation
through low-light enhancement and background removal with foundation models.